Move Robot to a Target Position
Function:
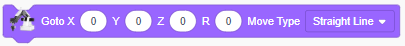
Description: Move robot to a target position in a certain motion mode
Parameter:
- X: Set X-axis coordinate value
- Y: Set Y-axis coordinate value
- Z: Set Z-axis coordinate value
- R: Set R-axis coordinate value
- Move Type:
- Joint
- Straight Line
- Return: null